Computer Vision & Embedded · 2026
IPDS: Intelligent Pothole Detection System
Real-time pothole detection with YOLOv8, dual ESP32 and accelerometer fusion
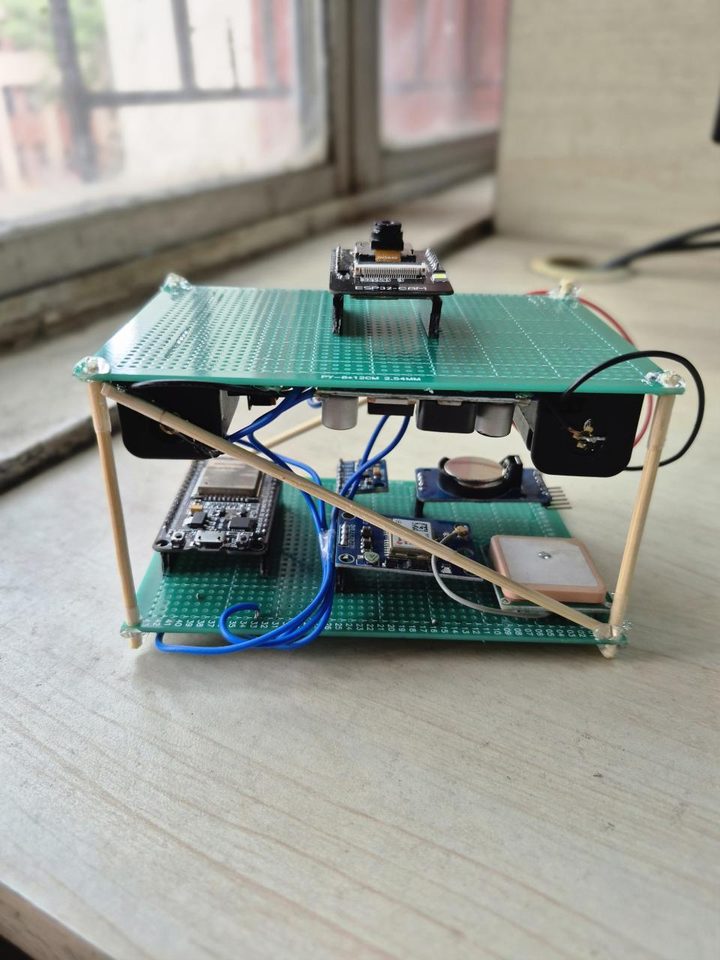
A low-cost dual-ESP32 and YOLOv8 rig that detects potholes in real time, tracks them, confirms each one with an accelerometer, and logs it with a severity score, GPS position and timestamp.
Most pothole projects stop at drawing a box on an image. IPDS goes all the way from the camera to a geo-tagged, severity-ranked maintenance log. A pothole is logged only when the camera sees it and the car feels it.
The work is written up as a research preprint, “Real-Time Pothole Detection Based on Vision-Dominant Sensor Fusion and Dual ESP32 Architecture”, published on Zenodo.
What it does
- YOLOv8m fine-tuned for potholes, reaching mAP@0.5 of 81.7%
- SORT tracking (Kalman filter and Hungarian matching) gives every pothole one stable ID, so it is counted once
- An MPU6050 accelerometer burst confirms the impact before anything is logged
- CSV log with GPS, RTC timestamp, a 0–1 severity score and an annotated video
- Custom sensor-node PCB designed in KiCad, plus a Wokwi simulation and a Colab quick start
Built with
- Python
- YOLOv8
- OpenCV
- SORT
- ESP32
- ESP32-CAM
- MPU6050
- KiCad